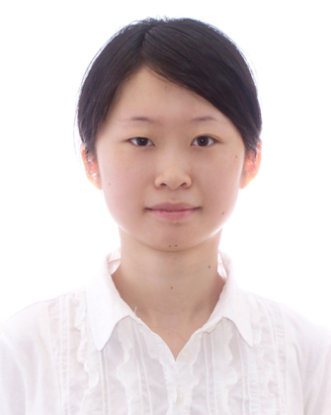
沈添天,女,博士,副教授,电子科学与技术、电子信息硕士生导师,湖南师范大学兼职心理咨询师, “世承人才计划”青年优秀人才; 香港大学电子与电机工程系高级研究助理,加拿大英属哥伦比亚大学高级协作机器人与智能系统实验室访问学者。主持国家自然科学基金,中国博士后基金,湖南省自然科学基金,参与国家重点研发计划等项目。
联系方式
E-mail:titiansaint@foxmail.com
通信地址:湖南师范大学工程与设计学院,410082
教育经历
09/2009~08/2013:香港大学,信息系统,工学博士,毕业论文:Visual Servoing Path-Planning for Generalized Cameras and Objects
09/2006~06/2009:北京大学,摄影测量与遥感,工学硕士,毕业论文:航空遥感成像高速数据存储系统的设计与实现
09/2002~07/2006:中国农业大学,测控技术与仪器,工学学士,毕业论文:基于Web的实验室资料管理信息系统开发
工作经历
01/2014~至今:湖南师范大学工程与设计学院电子工程系,讲师、副教授
04/2017~06/2019:中南大学自动化学院,在职博士后
09/2015~04/2016:香港大学工学院电子与电机工程系,高级研究助理
01/2012~06/2012:加拿大英属哥伦比亚大学,访问学者
研究方向
机器人传感与伺服控制技术、视觉伺服、视觉导航、路径规划
图像处理与模式识别、基于深度学习的古琴减字谱智能识别
招生信息
电子科学与技术(研究方向:信号处理与智能系统)
电子信息(研究方向:图像处理与模式识别)
主讲课程
本科生:信号与系统,复变函数与积分变换,专业英语
教学与科研获奖
1. 2015级湖南师范大学教育实习优秀指导老师
2. 2019国家级大学生创新创业训练计划项目结题优秀
3. 2019 FANUC杯 首届中国职业技术师范院校教学技能大赛三等奖
4. 2019指导优秀本科毕业论文:刘燊文,高分辨率雷达图像相干斑滤波研究
5. 2017科技创新成果一等奖:基于多传感器融合的多机器人智能喷涂系统
发表文章
1. H. Luo, T. Shen, W. Xu, Y. Zheng, L. Zhao, B. Zhou. Improved dripping algorithm based on modeling bidirectional splashes of water droplets. In 44th Chinese Control Conference, Chongqing, China, 2025(EI)
2. Longxu Zhao, Tiantian Shen, Qi Zhang, Mengyu Liu, Yu Zuo, and Mingrui Luo. Improved dripping algorithm based on modeling the backflow and splashing of water droplets. In 43rd Chinese Control Conference, pages 7717–7722, Kunming, China, 2024 (EI)
3. T. Shen, G. Chesi, Yao Hu, Jiahong Yang. Visual servoing path-planning for approaching cylindrical objects, JOURNAL OF THE FRANKLIN INSTITUTE - ENGINEERING AND APPLIED MATHEMATICS, 2023, 360(2): 735-758 (SCI)
4. G. Chesi, T. Shen. LMI-Based Determination of the Peak of the Response of Structured Polytopic Linear Systems. IEEE TRANSACTIONS ON CIRCUITS AND SYSTEMS I-REGULAR PAPERS, 2023, 70 (1): 435-446.
5. G. Chesi, T. Shen. On the impulse response peak of discrete-time uncertain LTI systems. IFAC PAPERSONLINE, 2023, 56 (2): 539-543.
6. T. Shen, M. Liu, M. Luo, Z. Peng, L. Wang, Semantic Recognition of Common Musical Notes in Guqin Score Based on Optimal Statistical Features, International Conference on Advances in Computer Technology, Information Science and Communications, CTISC 2022, Suzhou, China, April 22, 2022 (EI)
7. 沈添天,袁思敏,吴芳,陈中祥*,余果. 基于线性矩阵不等式的智能飞行器航迹规划方法[J]. 全球定位系统,2022, 47(2): 73-81
8. G. Chesi, T. Shen, “Convergent upper bounds of peak response of LTI and polytopic LTV systems through LMIs”, Automatica (online 18 Sept. 2020) (JCR Q1, SCI TOP) doi: 10.1016/j.automatica.2020.109260
9. G. Chesi , T. Shen, “ Designing parametric linear quadratic regulators for parametric LTI systems via LMIs”, International Journal of Control, vol. 92, no. 12, pp. 2907-2916, 2019. (JCR Q2)
10. X. Li, Y. Hu*, T. Shen, S. Zhang, J. Cao, Q. Hao, “A comparative study of several template matching algorithms oriented to visual navigation,” Proc. SPIE 11550, Optoelectronic Imaging and Multimedia Technology VII, 115500E (10 October 2020); doi: 10.1117/12.2573362 (EI)
11. 徐德刚,周雷,沈添天*. 基于线特征与内区域特征的视觉伺服解耦控制[J]. 信息与控制,2019,48(4):401-412. (CSCD)
12. T. Shen, S. Radmard, A. Chan, E. A. Croft and G. Chesi, “Optimized vision-based robot motion planning from multiple demonstrations,” Autonomous Robots, Vol. 42, Issue 6, pp.1117-1132, August 2018 (JCR Q2)
13. T. Shen, J. Yang, G. Chesi, “Inclusion of peripheral correspondences in object and pose estimation for visual servoing path-planning”, Proc IMechE Part I: Journal of Systems and Control Engineering, vol. 232, no. 3, pp. 336-247. SAGE, March 2018 (JCR Q3)
14. T. Shen, G. Chesi, “Visual servoing path-planning for cameras obeying the unified model,” Advanced Robotics, vol. 26, no. 8–9, pp. 843–860, 2012. (JCR Q4)
15. G. Chesi, T. Shen, “Conferring robustness to path-planning for image-based control,” IEEE Transactions on Control Systems Technology, vol. 20, no. 4, pp. 950-959, 2012. (JCR Q2)
16. T. Shen, G. Chesi, “Visual servoing path-planning with elliptical projections”. K. Madani, D. Peaucelle, O. Gusikhin (eds), Informatics in Control, Automation and Robotics, Lecture Notes in Electrical Engineering, vol. 430, pp. 30-54. Springer, Cham, 2018 (SpringerLink, EI)
17. G. Chesi, T. Shen, “On the Peak of the Impulse Response of Polytopic LTV Systems”, The 5th International Forum on Research and Technologies for Society and Industry (RTSI’2019), Firenze, Italy, 9-12 September 2019. (EI, oral)
18. G. Chesi, T. Shen, “A linear matrix inequality based strategy for maximum amplitude analysis in discrete time systems”, The 8th International Conference on Intelligent Systems and Applications (INTELLI’2019), Rome, Italy, 29 June-3 July 2019. (oral)
19. G. Chesi, T. Shen, “On the computation of the peak of the impulse response of LTI systems”, International Conference on Information Science and System (ICISS’2019), Tokyo, Japan, 16-19 March, 2019. (EI, oral)
20. Zhong-Wen Li; Li Yang; Tian-Tian Shen, “Study on real-time processing of spacecraft telemetry data”, 2019 4th International Conference on Automation, Mechanical and Electrical Engineering, Xiamen, China, 2019.10.27-2019.10.28 (EI)
21. T. Shen, D. Xu, W. Lu, J. Yang, “Robust visual servoing with spheres projected in cameras obeying the unified model”, Chinese Automation Congress. pp. 5602-5607. Jinan, China, 20-22 Oct., 2017 (EI, oral)
22. G. Chesi, T. Shen, “On the determination of parametric linear quadratic regulators for parametric systems”, PHYSCON. Florence, Italy, 17-19 July, 2017. (EI, oral)
23. T. Shen, J. Yang, Y. Cai, D. Li, G. Chesi, “Visual servoing with cylinders: reaching the desired location following a straight line”, in The 36th Chinese Control Conference. pp. 11183-11188. Da Lian, China, 2017. (EI, poster)
24. T. Shen, G. Chesi, “Following a straight line in visual servoing with elliptical projections”, in 13th International Conference on Informatics in Control, Automation and Robotics. pp. 47-56. Lisbon, Portugal, 29-31 July, 2016. (EI, oral)
25. T. Shen, S. Radmard, A. Chan, E. A. Croft and G. Chesi, “Motion planning from demonstrations and polynomial optimization for visual servoing applications,” in IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS’13), pages 578-583,Tokyo Big Sight, Japan, 2013. (EI, oral)
26. J. Li, G. Chesi and T. Shen, “On the stability of piecewise genetic regulatory networks”, in Proceedings of World Congress on Engineering, pages 1391-1396, London, United Kingdom, 2013. (EI, oral)
27. T. T. Shen and G. Chesi, “Visual servoing path-planning with spheres,” in International Conference on Informatics in Control, Automation and Robotics, pages 22-30, Rome, Italy, July 2012. (EI, oral)
28. T. T. Shen, “Motion and structure estimation for cameras obeying the unified model,” in International Federation of Automatic Control, pages 4747-4752, Milan, Italy, August 2011. (EI, oral)
29. T. T. Shen, G. Chesi, and Y. S. Hung, “A visual servoing path-planning strategy for cameras obeying the unified model,” in IEEE Multi-Conf. on Systems and Control, pages 1795-1800, Yokohama, Japan, September 2010. (EI, oral)
30. L. Yan, T. T. Shen, X. H. Duan, Y. K. Wu, S. H. Zhao, “Digital storage system for newly twice-imaging airborne camera device,” in 2nd International Symposium on Systems and Control in Aeronautics and Astronautics, pages 1-4, Shen Zhen, December 2008. (EI, oral)
授权发明专利
1. 沈添天,郑嫣,李果,魏湘,许文灏,吴知霖. 一种基于水滴双向飞溅的滴水路径优化生成方法. 中国专利:CN202411620314.1,2024-11-13. (申请发明专利)
2. 沈添天,阳春华,徐德刚. 一种机器人视觉特征规划轨迹的伺服跟踪加速收敛方法. 中国专利:CN202010143125.5,2022-02-01. (授权发明专利,已转)
3. 沈添天,袁思敏,陈中祥,阳春华,骆明锐. 一种面向移动柱状组合体的视觉伺服趋近方法. 中国专利:CN202011009179.9,2020-11-30. (授权发明专利,已转)
4. 沈添天,刘燊文,周雷,尹坤,胥佐君. 一种面向铸锭过程的锭块边缘检测方法. 中国专利:CN201910022360.4,2020-11-30. (授权发明专利,已转)
5. 沈添天,骆明锐,袁思敏,骆明垚,何儒,王露敏. 一种古琴减字谱指法的手写谱字识别方法. 中国专利:CN202010297656.X,2020-04-16. (授权发明专利)